Cho Hyeon Joon
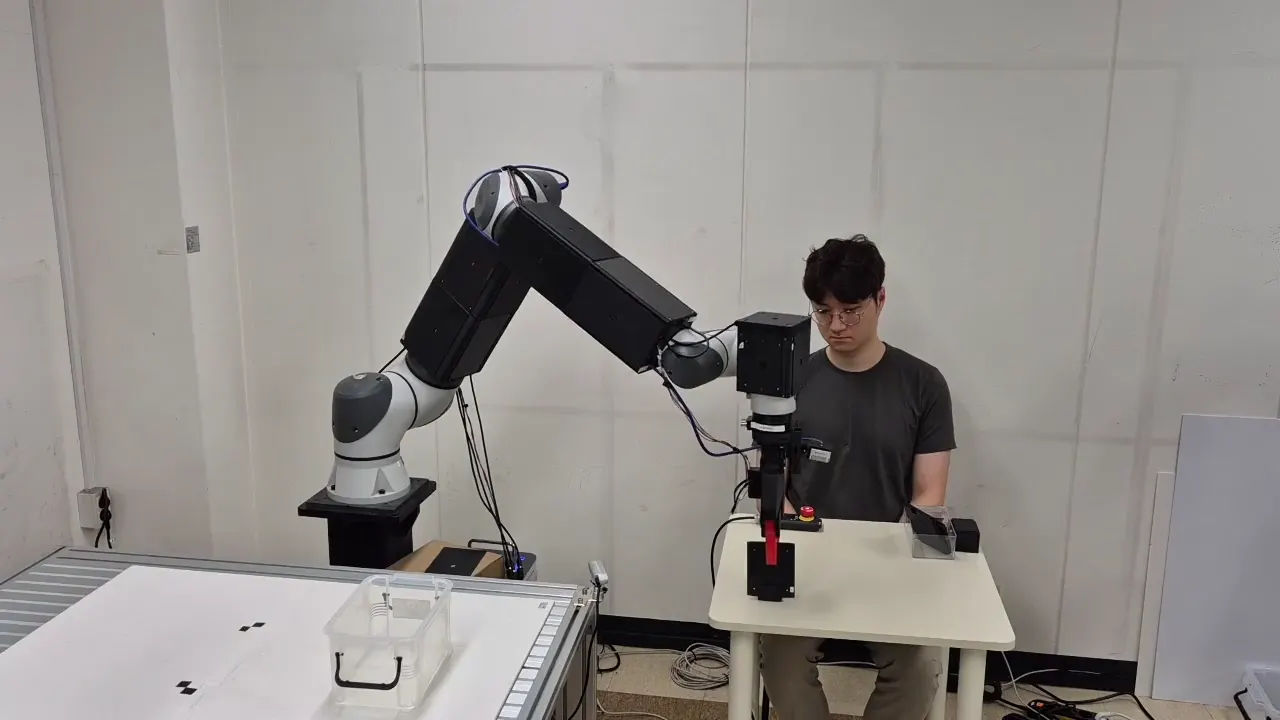
I work on robot learning for physical manipulation under distribution shift. My projects cover imitation learning, vision-language manipulation, and recovery after safety interventions, with most evaluation carried out on a real RB10 manipulator.
Most recently I designed a recovery-aware policy bridge for states created by reactive safety interventions. The proposed method completed 146 of 160 real-robot trials (91.3%), compared with 64.4% reported for the original LPB under the same intervention setting. A manuscript is in preparation.
Research
- Recovery-Aware LPB for RMP-Induced OOD States91.3% Recovery-aware LPB
- Force-Feedback Teleoperation for Real-Robot Imitation Learning9/10 Integrated final trials
- Grounded Language-to-Motion Planning with Memory and Gripper Constraints12/15 Improved system
- Zero-Shot Language-to-Motion Planning with Geometric ValidationZero-shot Planning setting